MorphoBot / Physical AI Hub / Responsible Simulation

MorphoBot Physical AI Hub

MorphoBot turns robot-control ideas into a hands-on workspace for exploring movement, teamwork, and the decisions behind each action. The current public experience helps teams try ideas, compare approaches, and turn promising experiments into shared knowledge, while keeping physical robot operation behind future safety, security, and operational validation.

Physical AI Robot Simulation Teamwork Demos Behavior Review Responsible Exploration
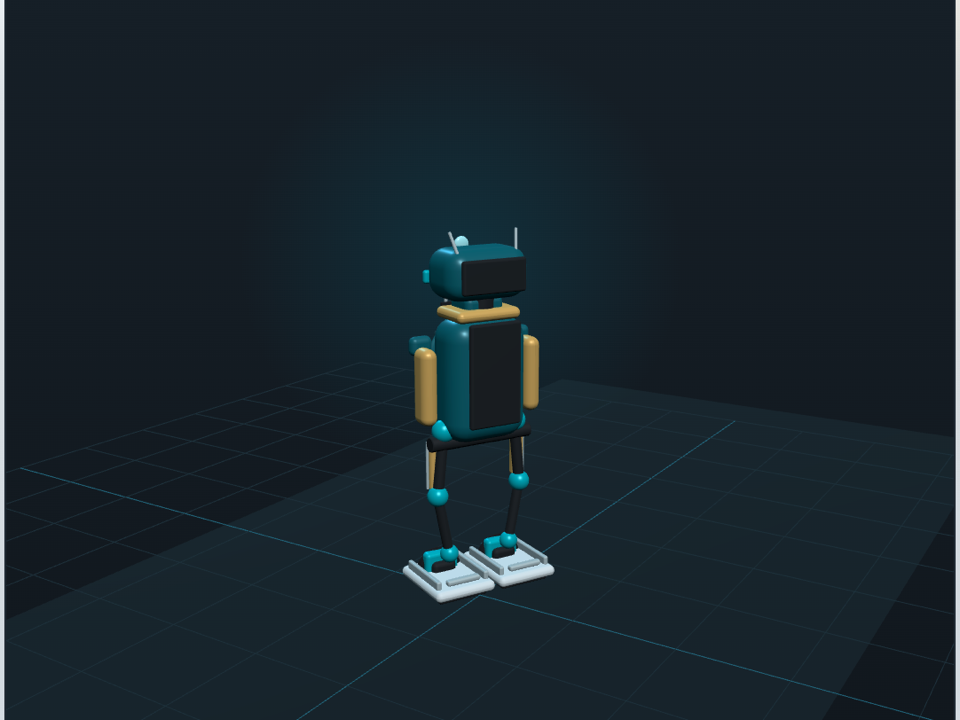
MorphoBot robot-control dashboard preview
Public demo preview for the Physical AI Hub and browser simulation surface.

Project Goal

Make robotics easier to explore by connecting the robot, the environment, and the people guiding the experience in one shared workspace. The product starts with simulation so teams can ask questions, compare approaches, review behavior, and turn experiments into insight before moving closer to physical testing.

My Contribution

Designed and implemented the public product experience and prototype flow: homepage narrative, interactive robot preview, simulator entry points, multilingual interface, workspace access, behavior-review framing, and the responsible-exploration language that helps users understand how to explore boldly while building toward physical systems carefully.

Public-Safe Scope

This page describes the live public prototype and visible product behavior. It excludes private credentials, local model caches, runtime databases, unpublished datasets, and internal deployment details.

Experience Design

Explore Movement

Let visitors meet the robot in 3D, inspect the model, try movement concepts, and see how an idea becomes an action.

Build Teamwork

Frame multi-robot and team scenarios as a way to understand coordination, shared goals, and the decisions that connect individual actions.

Learn From Trials

Keep the story of each run close at hand so teams can compare outcomes, revisit decisions, and turn observations into better experiments.

Build Responsibly

Make the simulation scope explicit: digital experiments are useful starting points, while physical robots need their own testing, authorization, and safety review.

Capabilities Built

  • Public homepage for MorphoBot Physical AI Hub with clear product positioning and responsible boundaries.
  • Embedded 3D robot model preview with controls for rotating and zooming the robot view.
  • Simulation entry points for individual movement exploration and teamwork scenarios.
  • Multilingual interface structure for English, Chinese, Japanese, and system-language mode.
  • Workspace entry flow for console access, login, saved work, and continued experimentation.
  • Experience framing for coaching, analysis, behavior review, repeatable team knowledge, and validated progress toward physical robot workflows.

Technical Shape

Public Surface Responsive MorphoBot homepage, live simulator preview, language switching, workspace entry points, and demo cards for movement and teamwork.
Exploration Flow Visitors can move from the public model preview into the workspace to explore robot motion, teamwork, coaching, analysis, and operations views.
Safety Boundary The page states the current scope clearly: digital exploration now, with physical robot operation requiring its own testing, safety, security, and operational review.

Design Principle

Treat Physical AI as a staged product experience: first make robot behavior visible, discussable, and repeatable in simulation; then use shared observations to guide deeper experiments and carefully validated physical steps.

Why It Matters

The project makes Physical AI approachable for robotics teams, educators, and curious builders. Instead of presenting robots as a black box, it gives people a place to explore choices, compare approaches, and turn experiments into confident next questions.